TapeSim: Efficient Simulation of Adhesive Tape Dispensing for Robotic Manipulation
Preprint; under review at ICRA 2027. Paper (arXiv v2)
Authors
Zhaofeng Luo, Xinyu Lu, Jaehoon Choi, Zhehuan Chen, Trinity Chung, Xiaowen Qiu, Hugh Nicholas Perkins, Gianna Calderon, Alexis Duburcq, Sanghyun Son, Tsun-Hsuan Wang, Yi-Ling Qiao, Minchen Li
My role: Sole first author.
Overview
Dispensing adhesive tape combines a flexible strip, a moving roll, and interfaces that repeatedly attach and detach. Resolving every wound layer is costly and can suppress roll motion at practical solver tolerances. TapeSim uses a rigid cluster for most wound material and an advancing deformable collar near the unwinding region, preserving a flexible, reattachable released strip.
Methods and Evaluation
- Reduced roll representation: localize deformation while allowing material to leave the roll.
- Adhesive interfaces: compare cohesive interfaces with optional releasable bonds.
- Solver evaluation: measure roll motion and physics-step cost under fixed tolerances and comparable motion.
- Robotics evaluation: use real-motion replays and paired real-to-sim manipulation cases, alongside a teleoperated packaging demonstration.
At 32 turns, clustering yields 3.2–3.4× mean physics-step speedups at a fixed Newton tolerance and 4.5–8.4× at comparable roll motion. These are physics-step measurements, rather than end-to-end application throughput.
Teleoperated Box Sealing
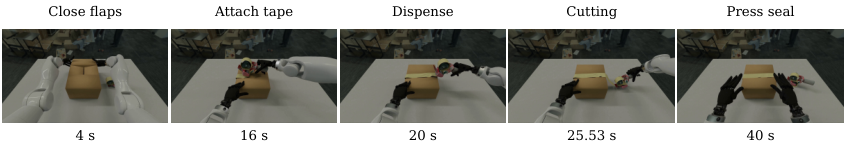
A simulated teleoperated sequence combines attachment, dispensing, cutting, and sealing in one continuous workflow. Figure from the paper.
Resources
Paper (arXiv v2) · Publication record
The paper states that source code will be released.