TapeSim: Efficient Simulation of Adhesive Tape Dispensing for Robotic Manipulation
Published in arXiv preprint, 2026
Zhaofeng Luo, Xinyu Lu, Jaehoon Choi, Zhehuan Chen, Trinity Chung, Xiaowen Qiu, Hugh Nicholas Perkins, Gianna Calderon, Alexis Duburcq, Sanghyun Son, Tsun-Hsuan Wang, Yi-Ling Qiao, Minchen Li
My role: Sole first author.
Preprint; under review at ICRA 2027. First posted September 23, 2026; revised September 28, 2026 (v2).
TapeSim concentrates deformation near the unwinding region and along the released strip. A rigid cluster represents most wound tape, while an advancing deformable collar enables payout. Released tape remains flexible and can reattach; optional releasable bonds provide a simplified adhesive interface.
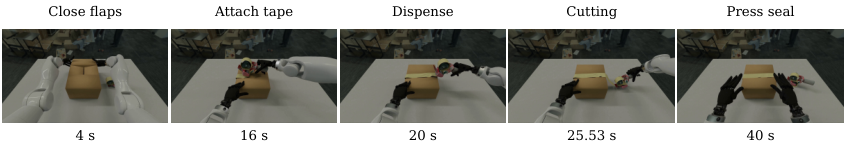
At 32 turns, clustering reduces mean physics-step time by 3.2–3.4× at a fixed Newton tolerance and 4.5–8.4× for comparable roll motion. Evaluation includes real-motion replays and paired real-to-sim manipulation cases. A teleoperated box-sealing sequence demonstrates attachment, dispensing, cutting, and sealing.
Paper (arXiv v2) · Project overview